Gemini Robotics 2 brings whole body intelligence to robots
Google DeepMind · 2026-07-30 · official · 5,295,644 views
What's in the video
Description written by Gemini, which watched and listened to the whole video.
Summary
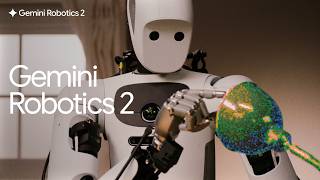
This video is an official launch showcase from Google DeepMind introducing Gemini Robotics 2, a multimodal generalist foundation model designed to serve as an intelligent physical "brain" across diverse robotic embodiments. Researchers including Jie Tan, Marissa Giustina, Kanishka Rao, Konstantinos Bousmalis, and Stuart Bowers discuss and demonstrate the model’s capabilities across whole-body humanoid control, fine dexterity, and multi-robot collaboration.
What is shown
- [00:00] Humanoid robot Apollo conversing naturally with an interviewer on a film set.
- [00:04] A robotic arm delicately inserting an audio cassette into a retro boombox.
- [00:14] Apollo autonomous squatting down to retrieve a watering can from the floor.
- [00:27] Split-screen clips comparing human motions to robotic actions: carrying crates, bouncing a ball with a table tennis paddle, and closing a zip-lock bag of grapes.
- [00:36] Various manipulation skills: wiping counters, slotting books into a tight bookshelf, preparing tea cups, and inserting an Atari cartridge into a console.
- [01:13] Pillar 1 ("Intelligent Whole-Body Control"): Apollo managing full-body coordination to pick objects off low shelves and move tool bags.
- [01:31] Pillar 2 ("Advanced Dexterity"): Robotic hands performing high-precision tasks such as extracting screwdriver bits from an organizer, screwing a lightbulb into a desk lamp fixture [01:38], and manipulating plastic trash bag drawstrings [01:49].
- [02:04] Pillar 3 ("Multi-Robot Collaboration"): Apollo and stationary dual-arm setup "Duo" responding to spoken instructions to kit tools and organize a bin, with on-screen reasoning overlays showing decentralized task allocation.
- [02:33] Robustness to environment perturbation: An engineer uses a pole to nudge a striped laundry tote across the room; Apollo observes the disturbance, adapts its gait and trajectory, and successfully picks it up.
Claims & numbers
- On-screen caption claims: "All robots in this video are fully autonomous with Gemini Robotics 2. Real-time footage." [00:15]
- Marissa Giustina states that operating the dexterous robotic hand requires controlling 22 separate joints simultaneously [01:56].
- Jie Tan states the Gemini Robotics 2 release focuses on three primary pillars: Intelligent Whole-Body Control, Advanced Dexterity, and Multi-Robot Collaboration [01:10].
- Stuart Bowers claims that during multi-robot collaboration, the robots do not rely on a single centralized controller; each robot runs its own independent instance of the model stack and coordinates via autonomous reasoning [02:20].
Notable quotes
- [00:40] "The key difference in Gemini Robotics 2 is we aim to build a generalist robotics model that is going to add a lot more value if one robot can do a lot of different tasks." — Jie Tan
- [01:00] "The way to think about is the brain, Gemini Robotics, is what controls the whole body of the humanoid, the delicate movements of the Shadow hand, and the grippers..." — Konstantinos Bousmalis
- [02:21] "Rather than having one neural network that controls both robots, each have their own copy and they're each doing their own individual thinking, and they're actually orchestrating through reasoning." — Stuart Bowers
Assessment
This is an official Google DeepMind engineering launch video displaying verified physical autonomous demonstrations across various hardware setups (Apptronik Apollo humanoid, bimanual arm tables, and multi-finger robotic hands). While the footage shows real-time autonomy and closed-loop disturbance recovery, the tasks are conducted in curated laboratory conditions designed to highlight ideal performance.
Described by gemini-3.8-flash on 2026-09-29 from the video's audio and frames.